Research
My research in localization for field robots. Papers are listed on the home page and in the CV.
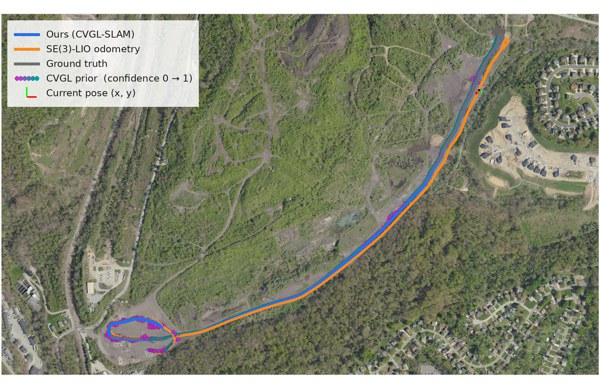
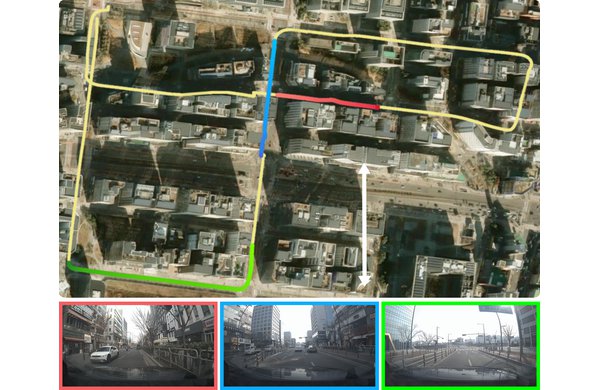
Bounds odometry drift without loop closure by matching the robot's view to satellite imagery and adding confident matches to a pose graph.
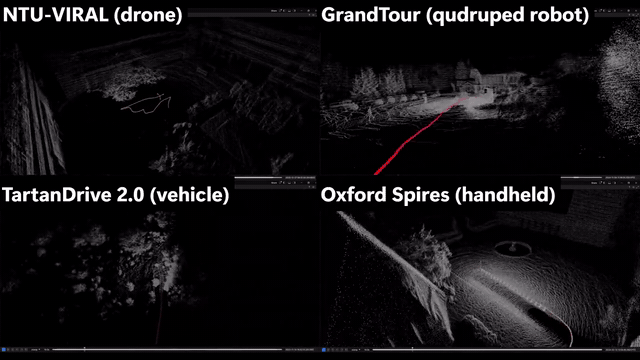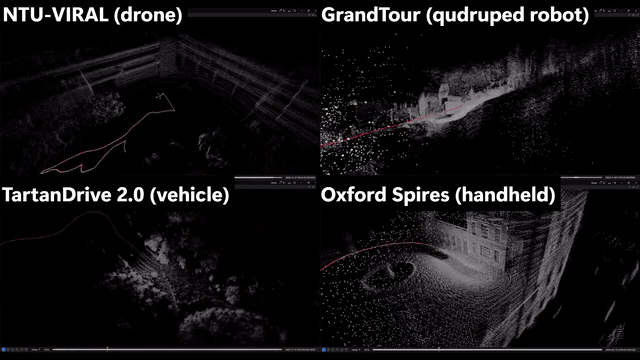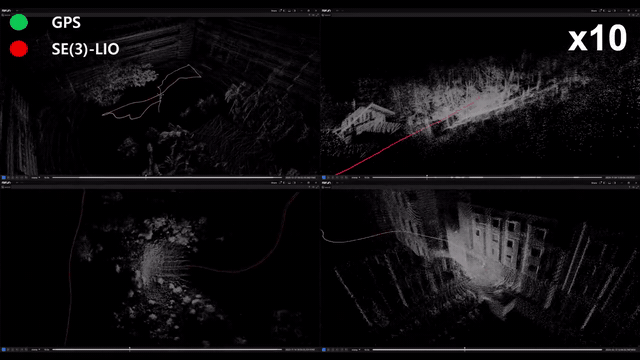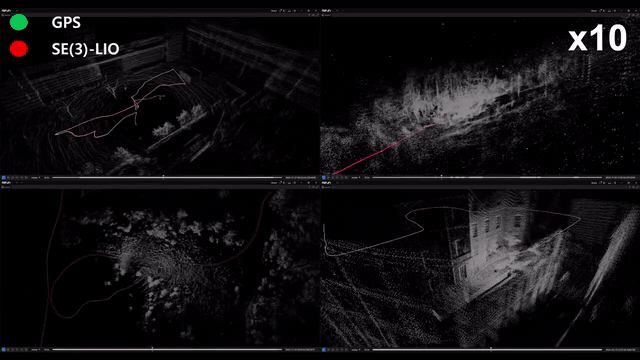
LiDAR-inertial odometry that propagates the IMU state jointly on SE(3), staying accurate under fast motion and vibration.
Online Target-less Radar-LiDAR-Camera Extrinsic Calibration via Joint Optimization
Online calibration of radar, LiDAR, and camera without targets, optimizing all three sensor pairs together.
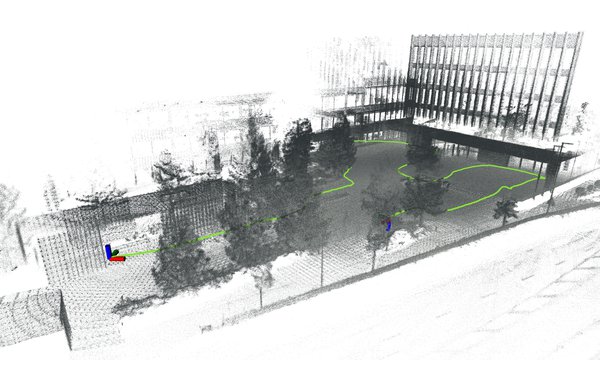
NM-LIO: Multiple LiDAR-Inertial Odometry Addressing LiDAR Measurement Noise Discrepancy
Multi-LiDAR inertial odometry that models the measurement noise of each LiDAR.