2nd Place
Quadruped Robot Challenge
Overview
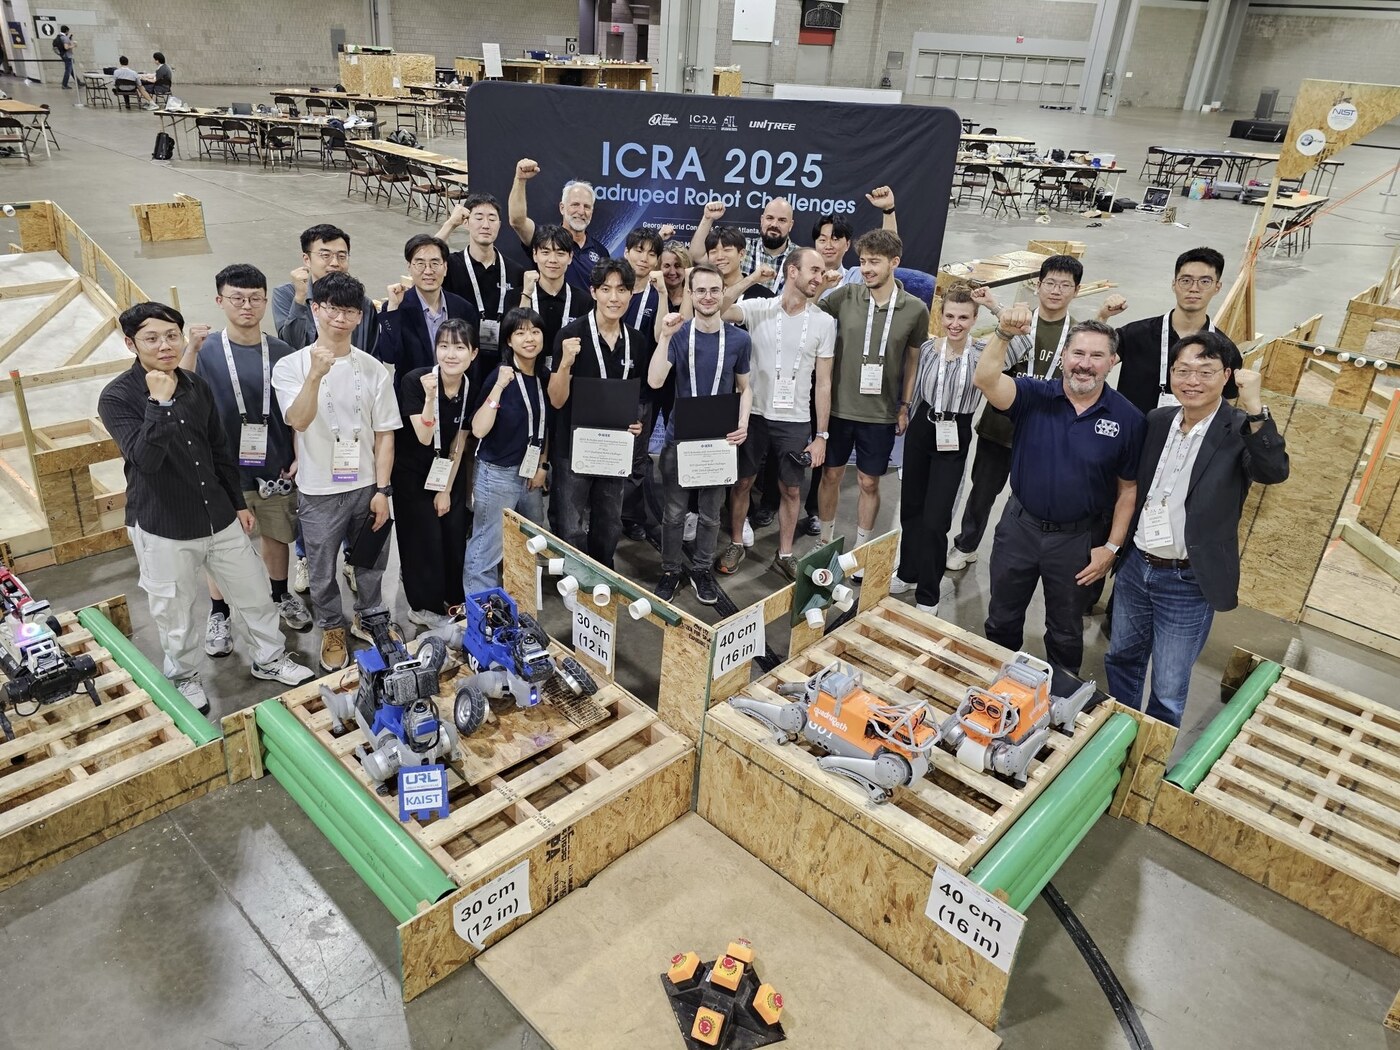
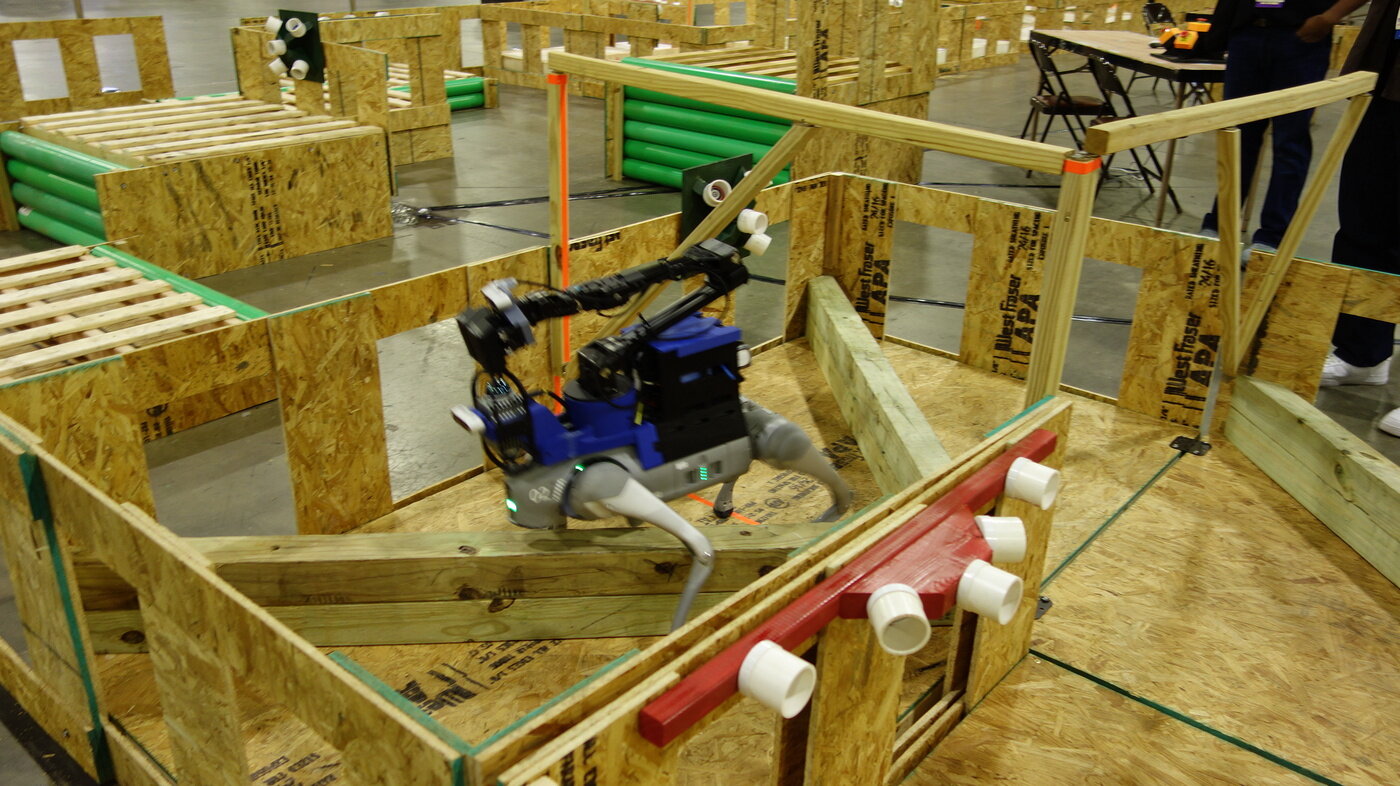
- Legged robots cross rough-terrain lanes and do inspection and button tasks; autonomy scores more.
- Steps, slopes, and ramps; the robot falls and shakes, so odometry must recover from failure.
- 2nd of six teams (with Caltech and ETH Zurich in the field).
Platform
Unitree Go2 with a ViperX arm
Sensors
Two Livox Mid-360, Xsens IMU, two RGB-D
Environment
Lanes of steps, slopes, and ramps
Venue
ICRA 2025, Atlanta
My part
My Part
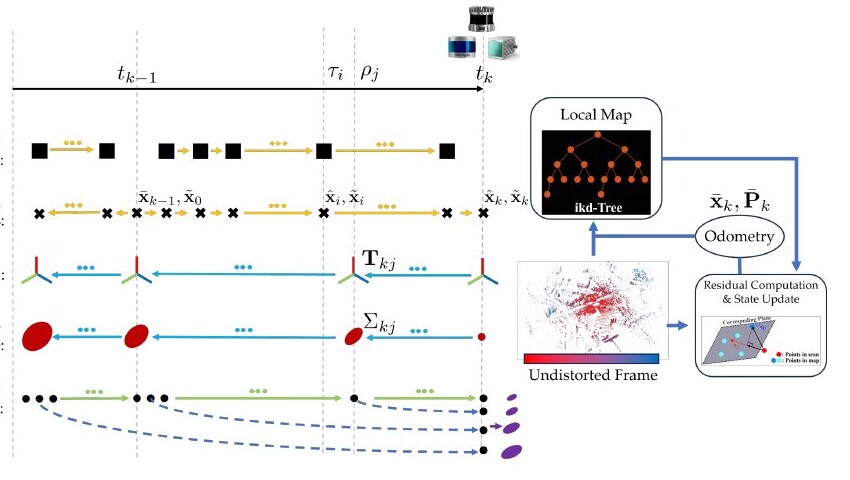
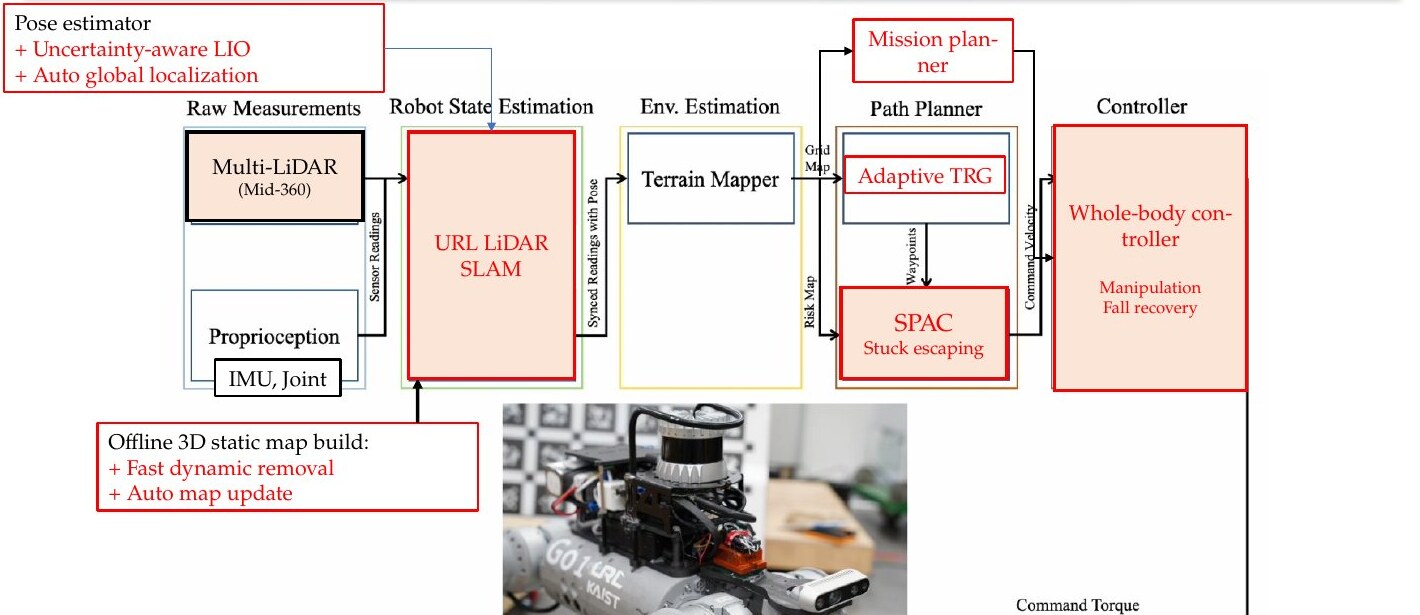
New LiDAR-inertial odometry
Replaced the FAST-LIO filter with our own SE(3) state and uncertainty-aware motion compensation. It later became SE(3)-LIO.
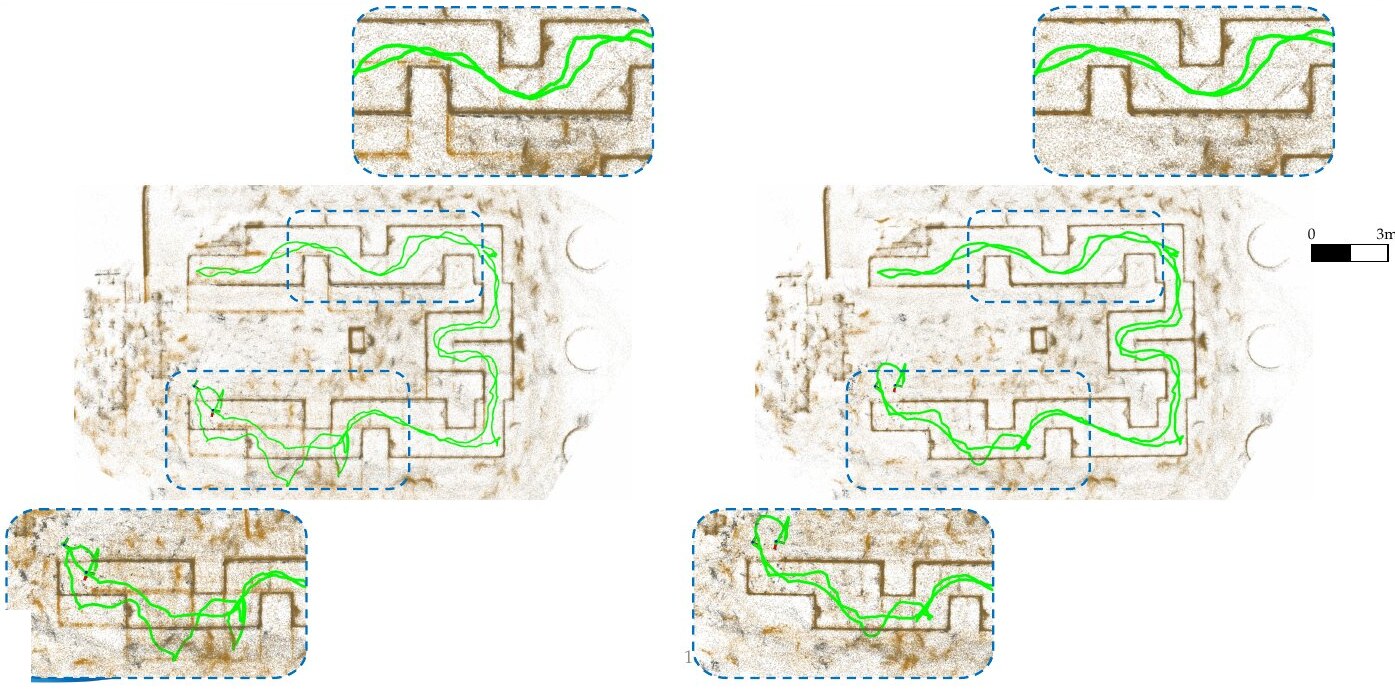
Recovery
A divergence handler resets the pose by global localization; a synchronizer keeps going when a LiDAR drops out.
Calibration on site
Recalibrated the LiDARs at the venue after they shifted on their mounts.
Award