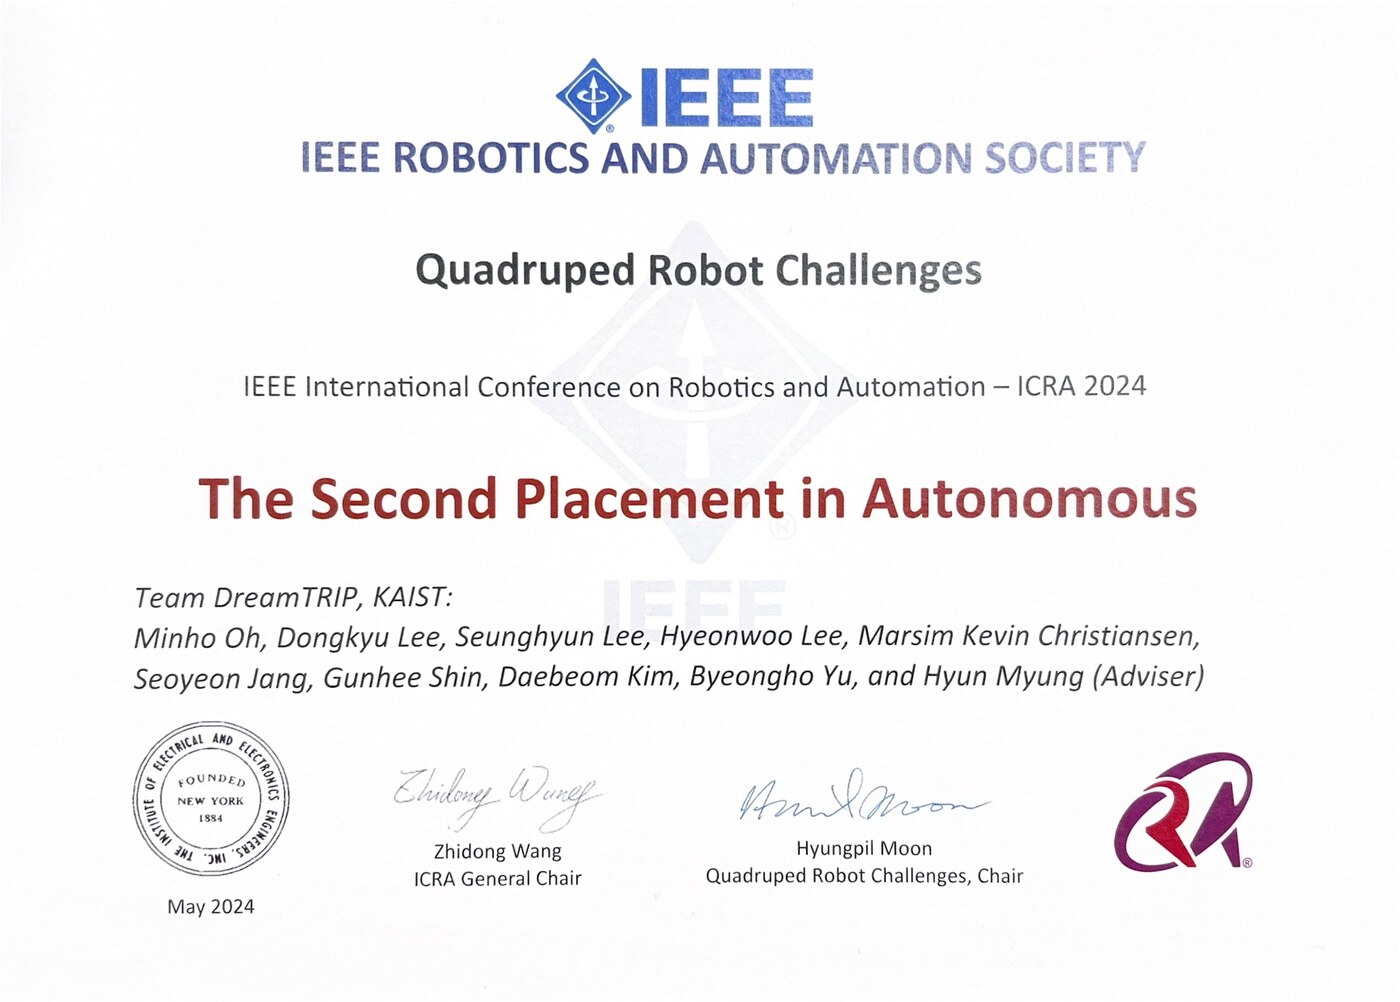
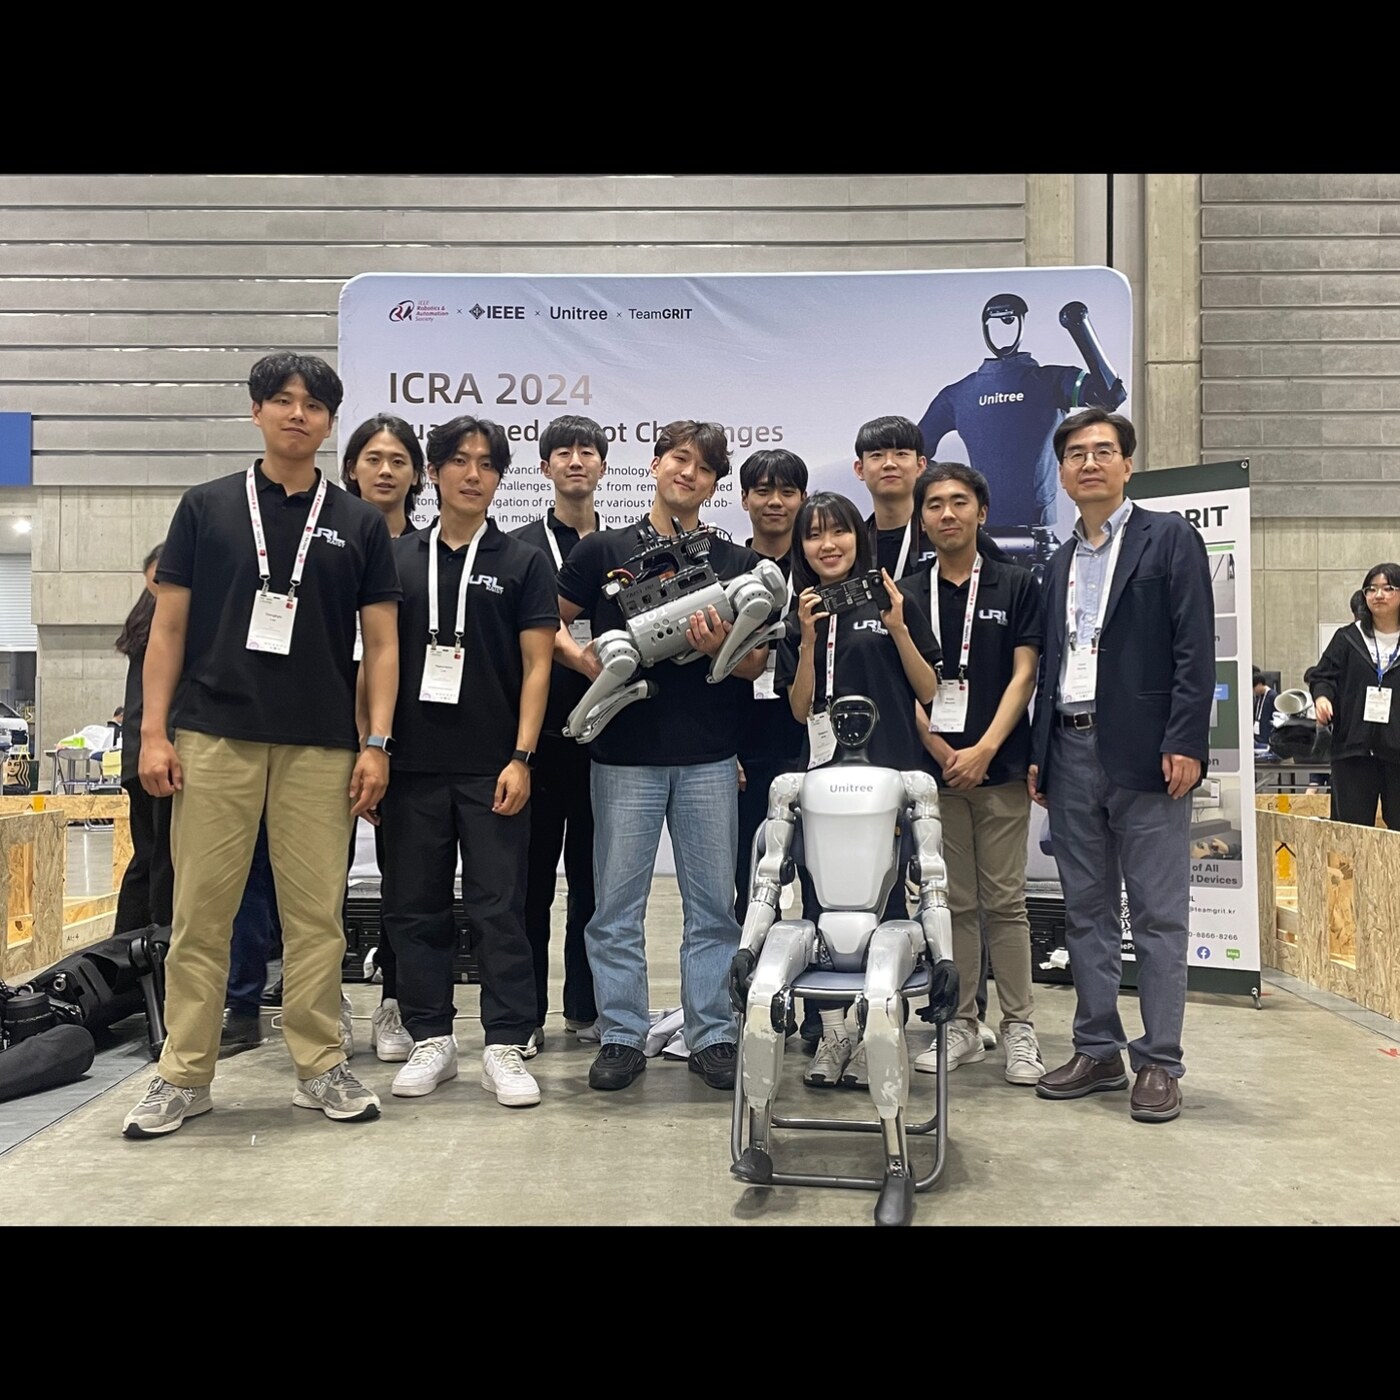
2nd Place
Quadruped Robot Challenge (Autonomous Track)
Overview
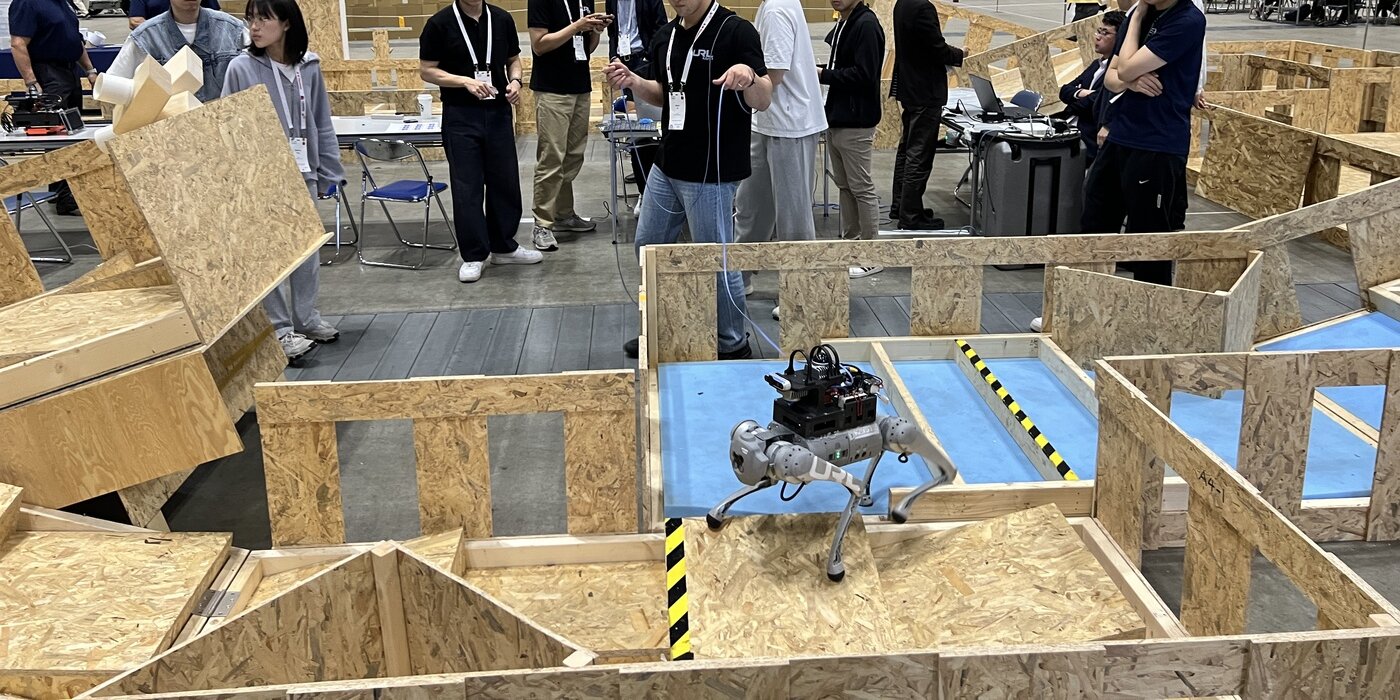
- Legged robots lap a rough-terrain course autonomously for 10 minutes, onboard sensing only.
- Ramps, steps, falls, and crowds at the walls; a localization failure ends the run.
- 2nd in the autonomous track.
Platform
Unitree quadruped
Sensors
Two LiDARs, IMU
Environment
Tight course with ramps and steps
Venue
ICRA 2024, Yokohama
My Part
Map-based localization
LiDAR-inertial odometry inside a static prior map, operated during the runs.
Two-LiDAR input
Kept the odometry running when one LiDAR stopped or lagged on an unstable cable.
Tuning benchmark
A benchmark to pick one parameter set that works across environments.
Award