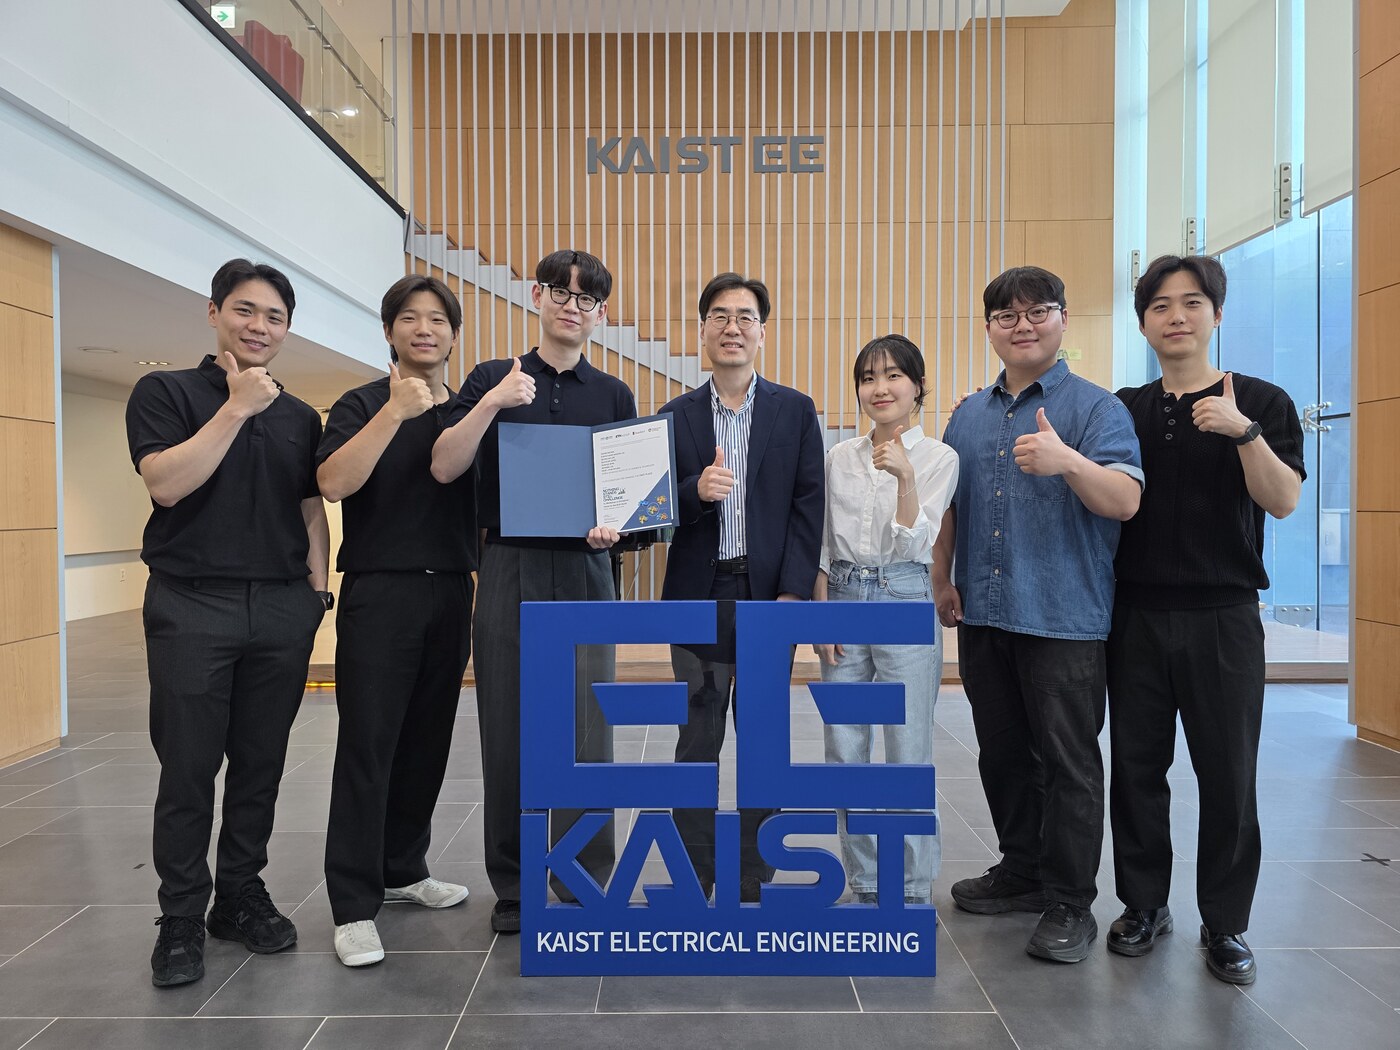
Winner
Nothing Stands Still Challenge
Overview
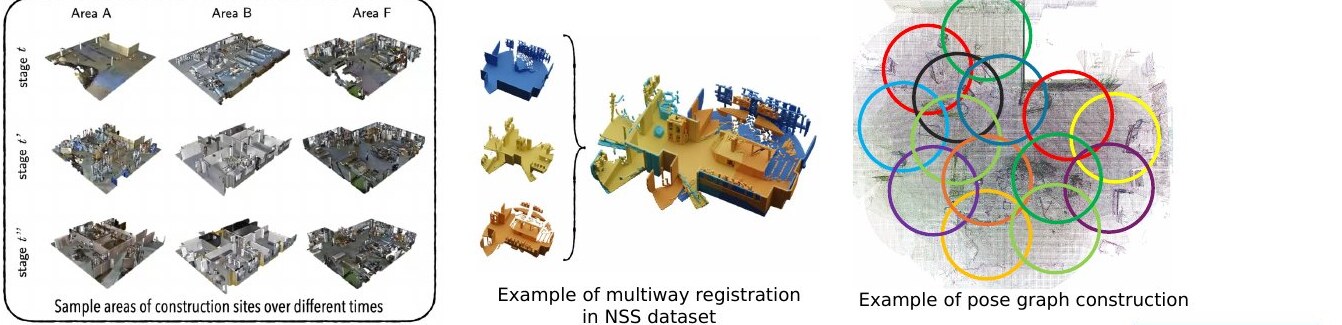
- Align indoor scans of buildings at different construction stages into one frame.
- Overlaps are unknown, walls come and go between stages, and up to 10 % of scans are outliers.
- 1st place. Global RMSE 0.65 m vs. 2.78 m for the runner-up.
Sensors
3D point-cloud scans
Environment
Six building construction sites, 2 to 6 stages each
Graphs
20 to 240 scans each
Metric
Global RMSE, outlier F1
My part
My Part
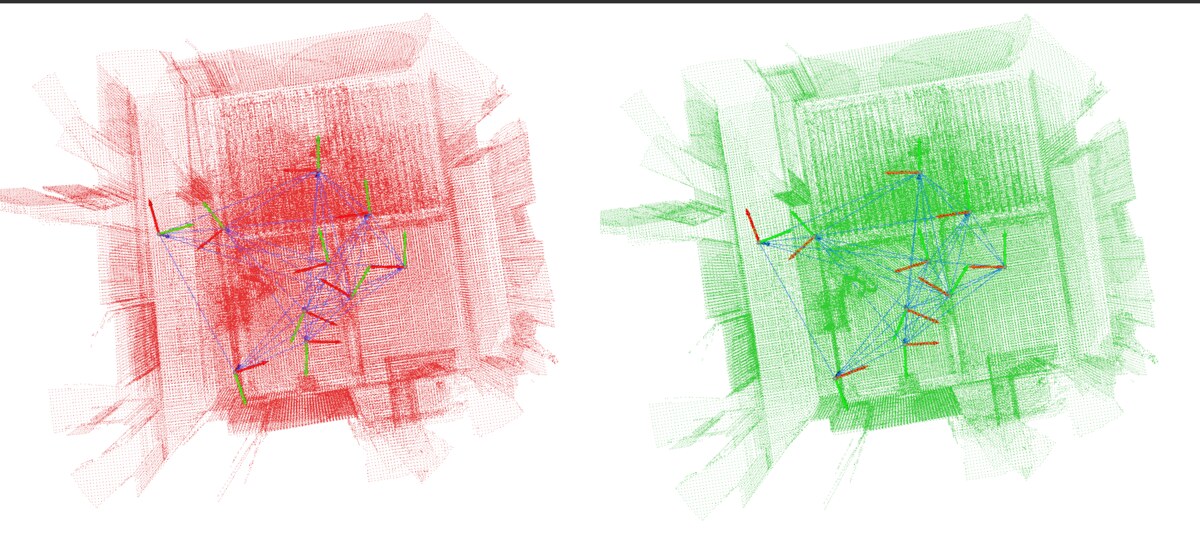
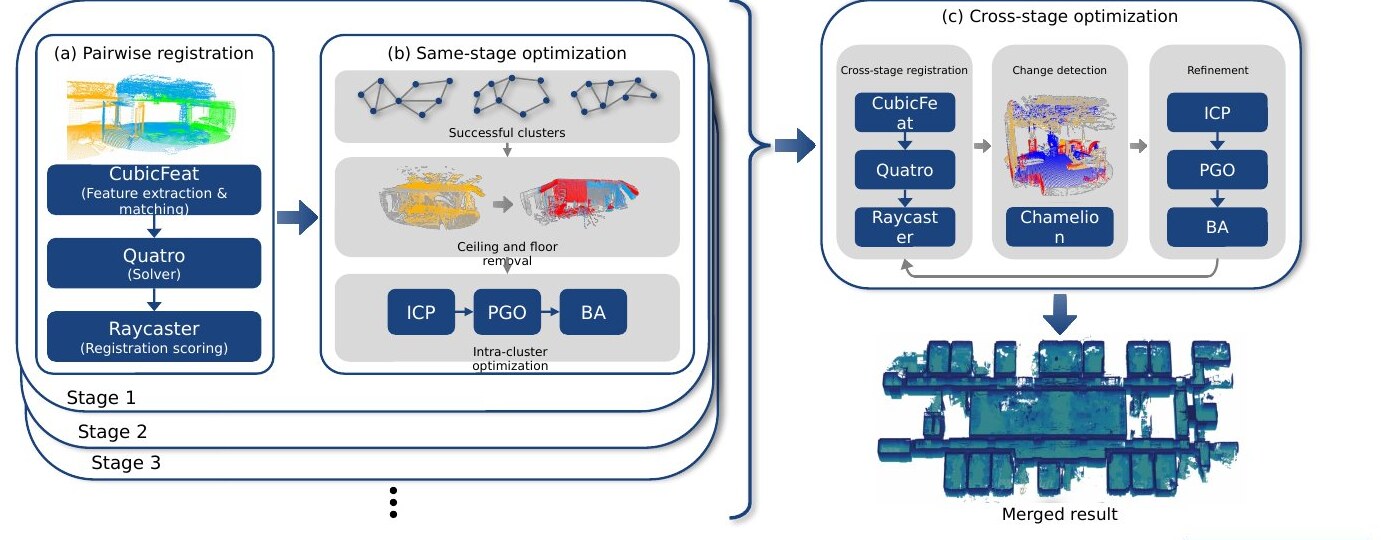
Recursive subgraphs with PGO
Accepted pairs form subgraphs, leftover scans are retried, and each subgraph is refined by pose graph optimization.
Translation error 0.084 → 0.037 m (validation)
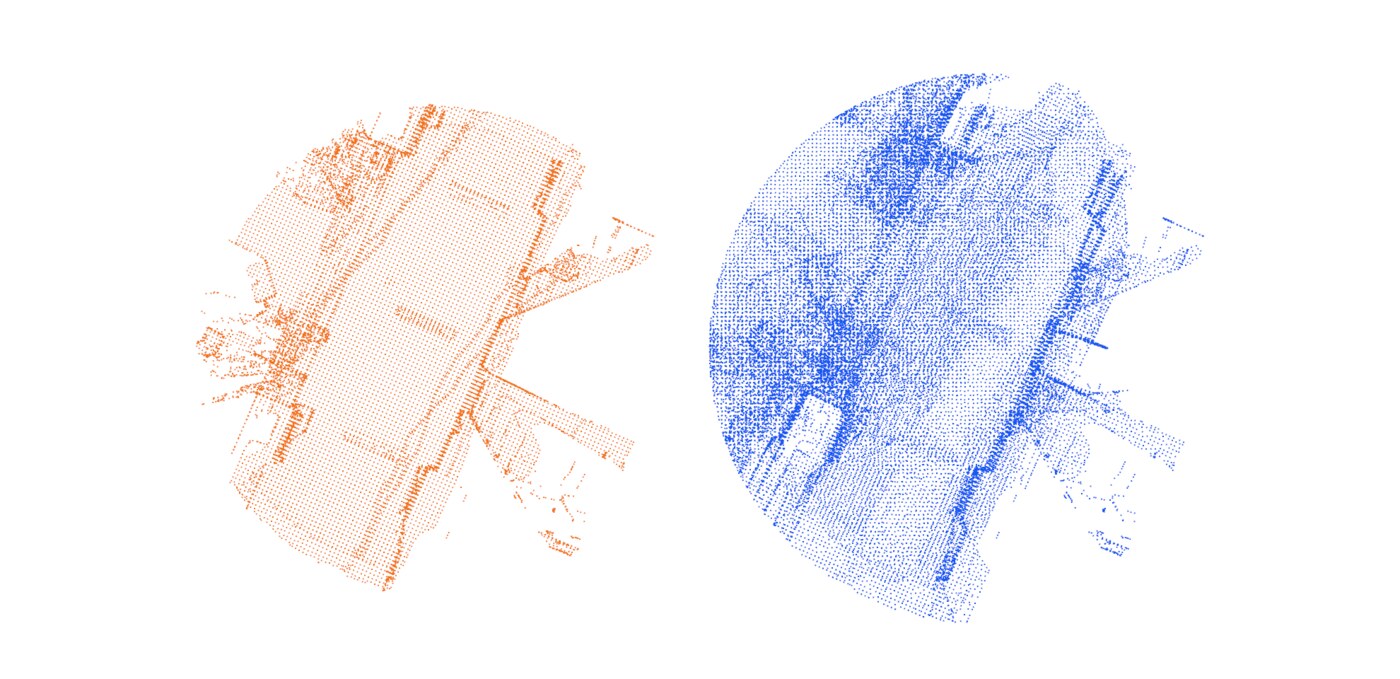
Matching between clusters
Scale-adaptive BUFFER-X between clusters; leftover scans densified with their neighbors, then re-matched.
About twice the points per densified scan
| Rank | Team | Global RMSE (m) | Outlier F1 |
|---|---|---|---|
| 1 | Curaytor (ours) | 0.65 | 95.69 |
| 2 | GTS3D | 2.78 | 39.25 |
| 3 | C3DV Team | 8.34 | 25.44 |
Final leaderboard, top 3.
Award