Semantic SLAM for Spatial AI
Confidential project. Internal figures and numbers are not shown.
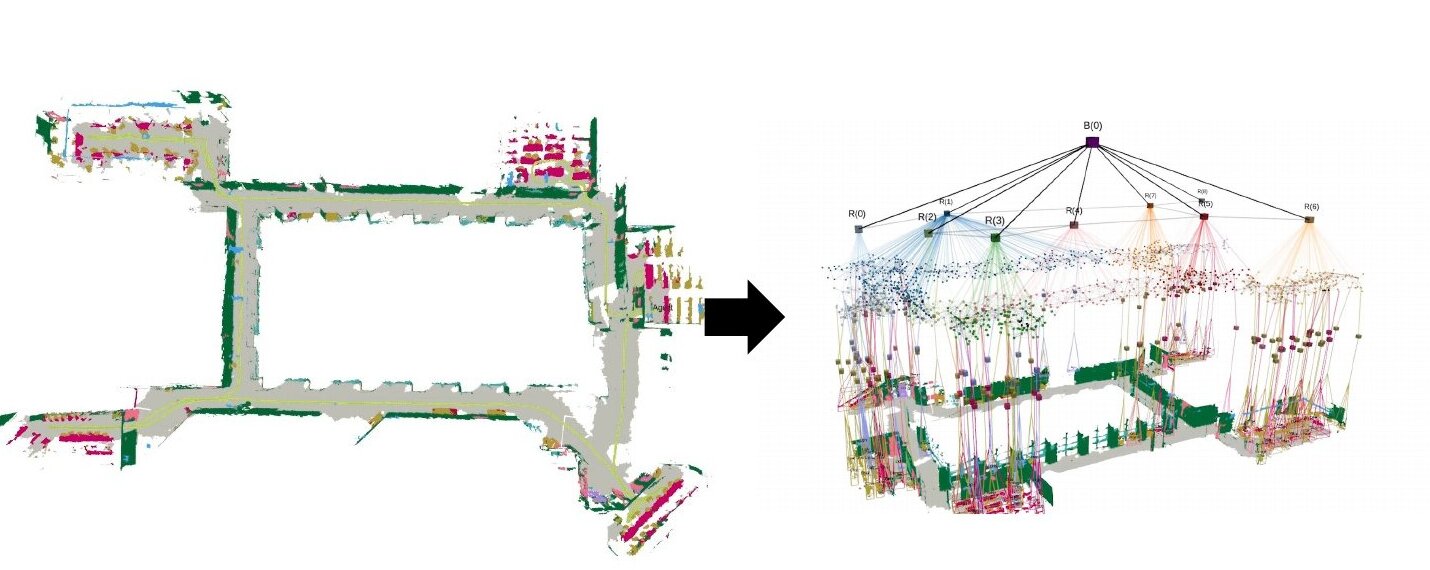
Overview
- Run a 3D scene graph SLAM (Hydra, MIT) on real sensors instead of simulation.
- Goal: a robot told “go to the fridge” instead of given coordinates.
- Delivered a semantic SLAM survey and a real-building evaluation with three improvement directions.
Platform
Handheld rig
Sensors
Depth camera, RGB camera, IMU
Environment
Two floors of a KAIST building
Sensor inputsdepth, semantics, odometry
Mesh and places
Objects and rooms
Loop closing
Highlighted: my part.
My Part
Real-sensor inputs
Depth, semantics (HRNet trained on ADE20K, mapped to 20 classes), and odometry wired into Hydra.
Loop closing with Quatro
Replaced TEASER++ with our gravity-aligned Quatro; revisited floors stopped drifting apart in height.