Online Radar-LiDAR-Camera Calibration for Autonomous Vehicles
Confidential project. Figures and results shown are from the published paper.
Overview
- Keep radar, LiDAR, and camera on a vehicle calibrated to each other while it drives, with no target.
- Then use the calibrated sensors for simultaneous calibration, localization, and mapping.
- First-year targets met; published as a first-author paper at ICCAS 2026.
Platform
Passenger vehicle
Sensors
4D radar, LiDAR, camera
Environment
Urban driving
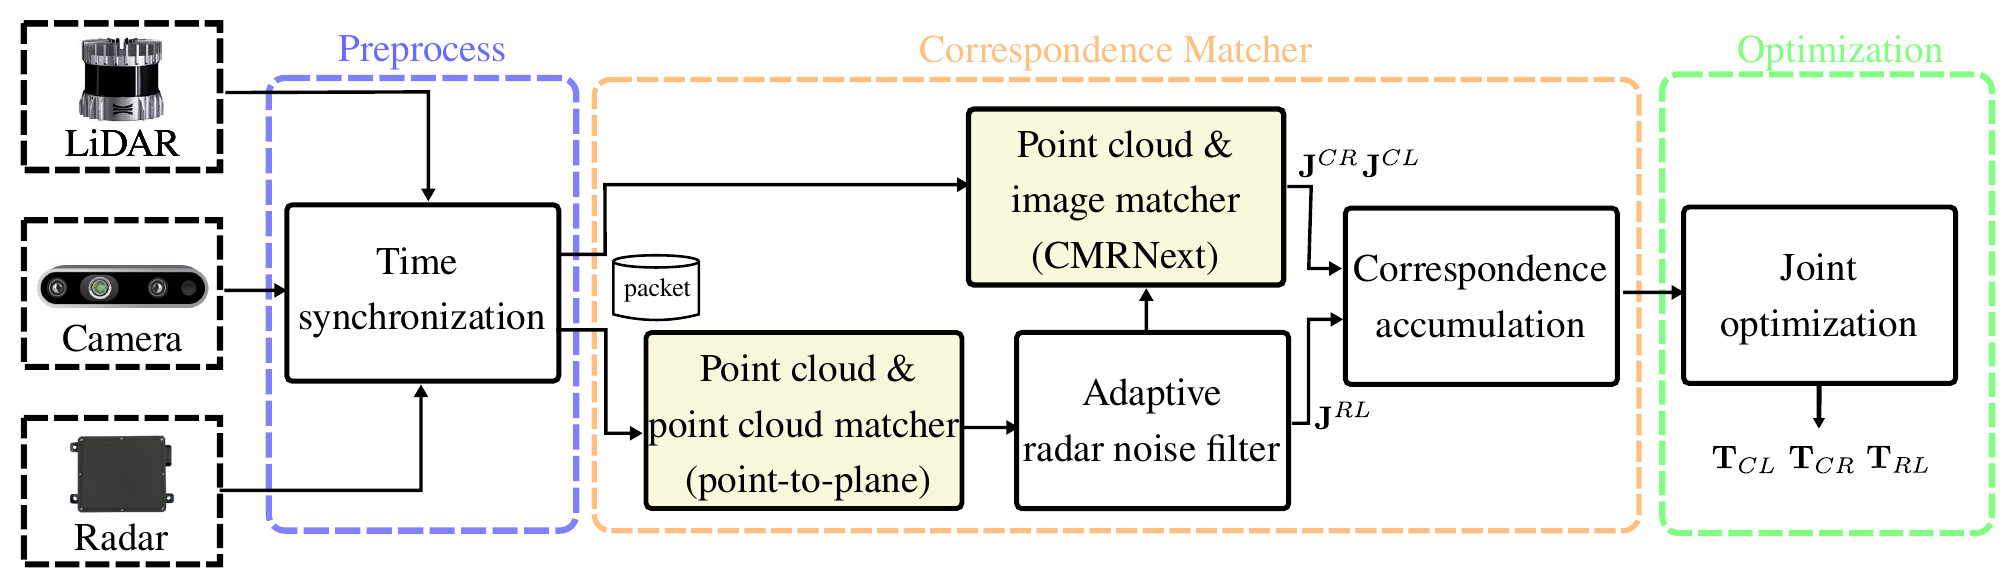
My Part
Lead developer, planning to evaluation
Targets, every module, vehicle data and ground truth, and the evaluation.
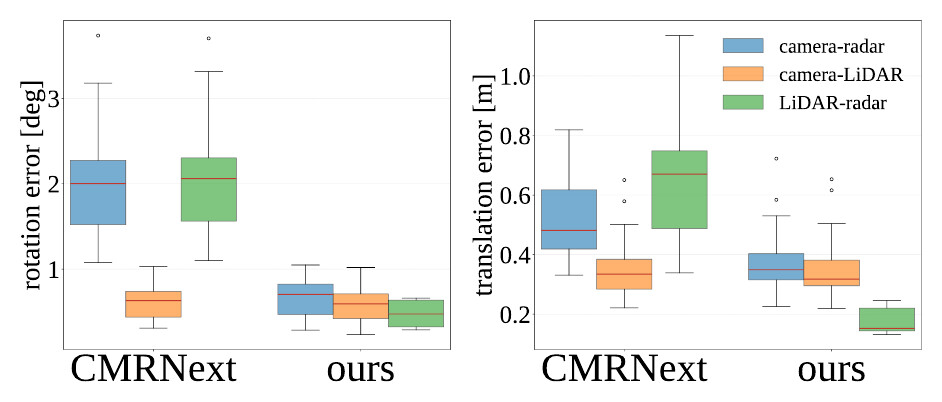
Joint optimization over all three pairs
All three extrinsics optimized together, so the strong camera-LiDAR pair stabilizes the radar pairs.
Lower error on all pairs; largest gain with radar
Making radar usable
An adaptive radar noise filter and accumulation of sparse radar matches over frames.