Winner
HILTI SLAM Challenge (LiDAR Single-Session)
Overview
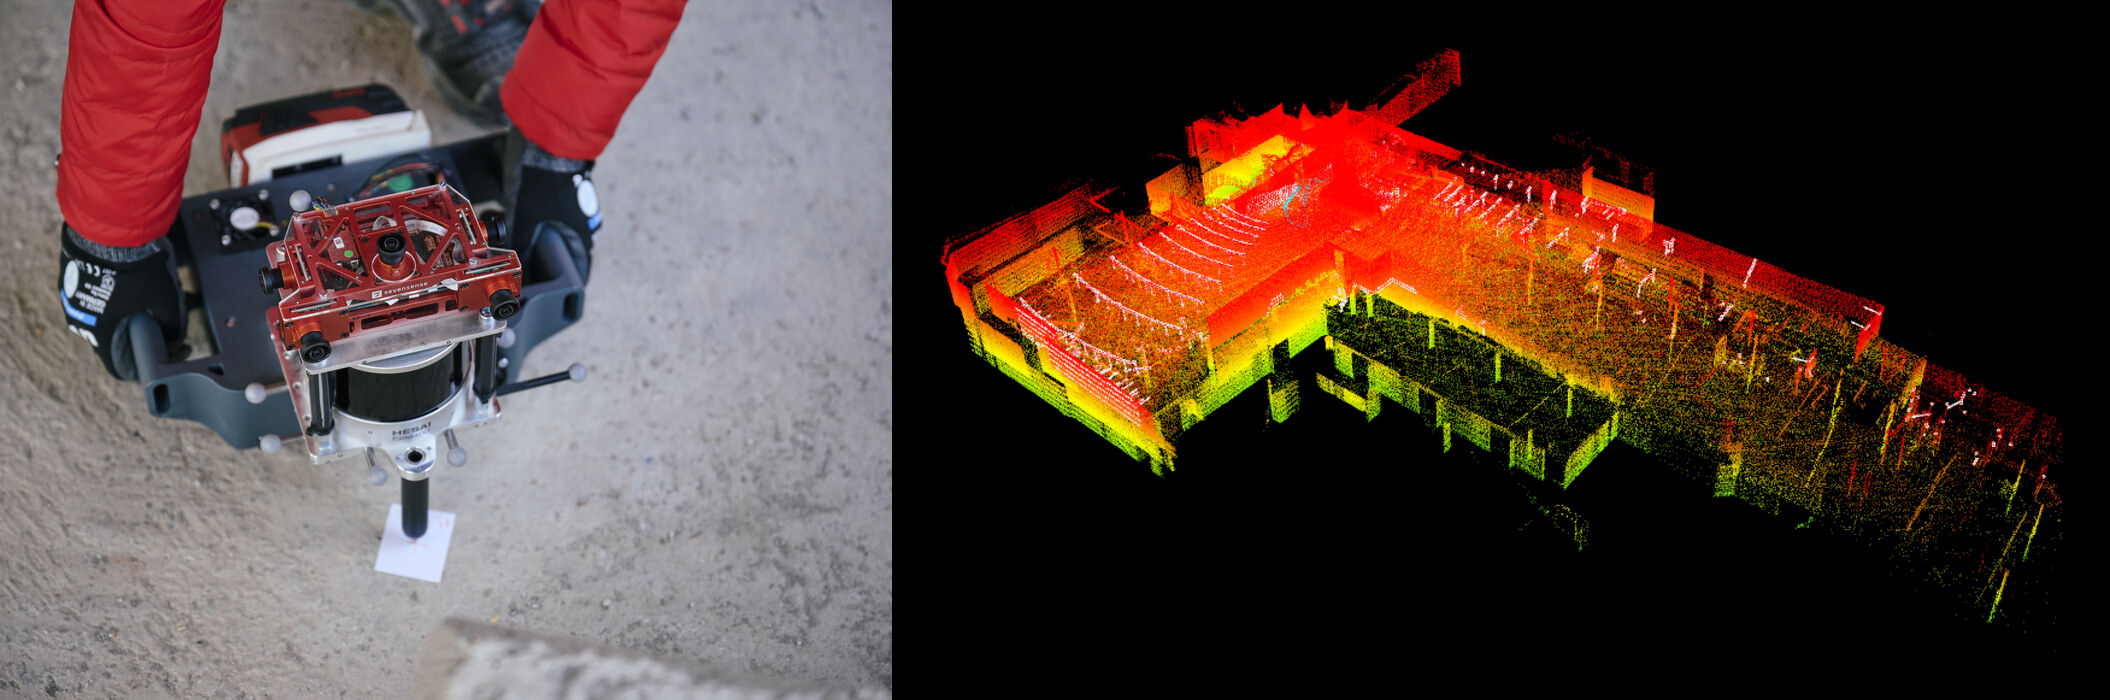
- LiDAR SLAM on construction sites, from a handheld rig and a tracked robot.
- The operator walks right up to walls, so the LiDAR sees only a small patch and odometry diverges.
- 1st of 63 teams in the LiDAR session (3,000 CHF), a year after 4th overall in 2022.
Platform
Handheld rig and tracked robot
Sensors
Hesai 32 (handheld), Robosense (robot)
Environment
Construction sites, one underground
Metric
Score by position error, max 1600
My Part
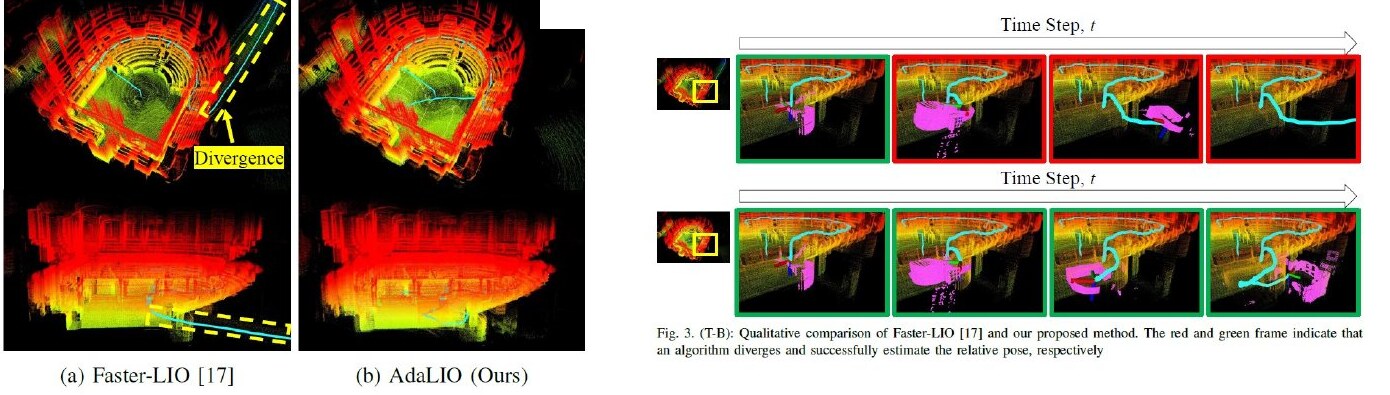
AdaLIO on every sequence
Our adaptive odometry changes its parameters when a scan is degenerate. I tuned and ran it per sequence.
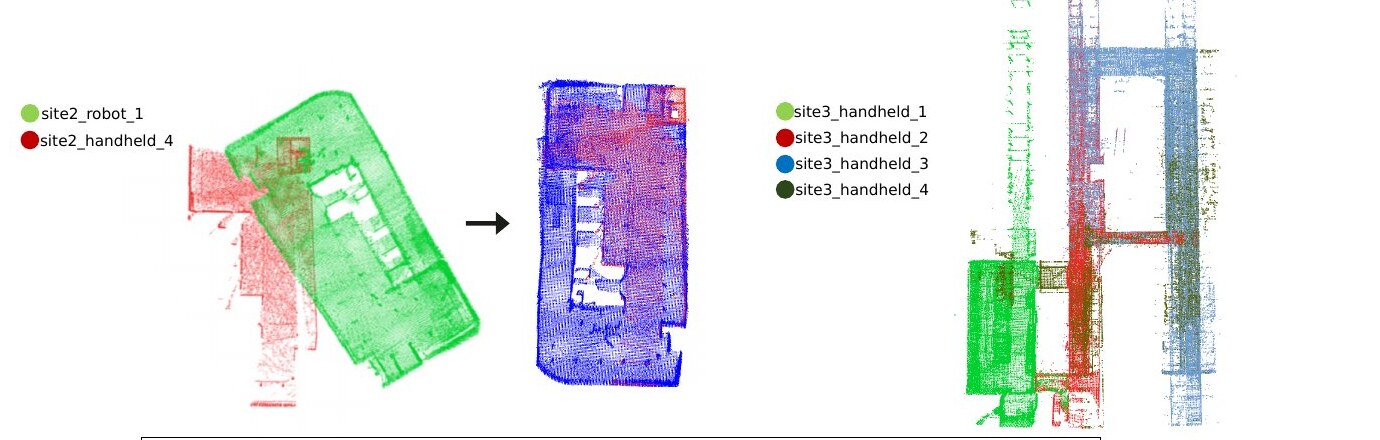
Multi-session alignment
Quatro for a global guess, G-ICP to refine, then a multi-session pose graph.
Award