Off-Road Autonomous Driving in Unstructured Terrain
Confidential project. Figures and numbers shown are from the published paper.
Overview
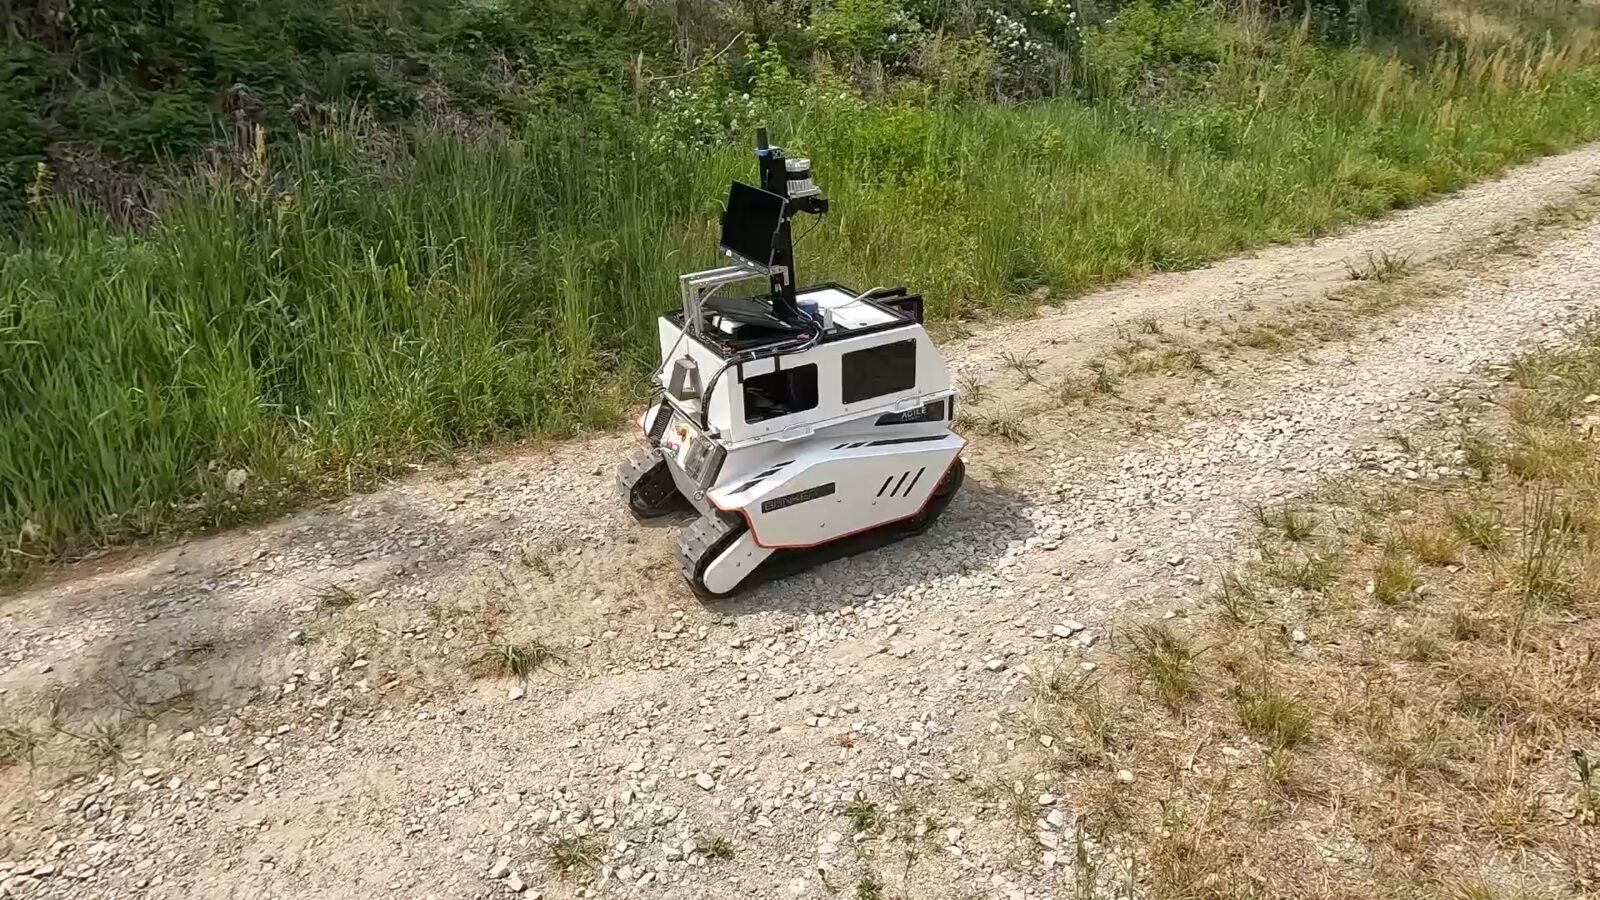
- An unmanned ground vehicle drives through unmapped off-road terrain while GPS is jammed.
- Absolute position comes from matching satellite images; everything else from onboard sensors.
- All quantitative targets met; closed in 2026 with an integrated field demo.
Platform
Tracked ground vehicle
Sensors
128-channel LiDAR, cameras, IMU
Environment
Forest, open fields, steep dirt tracks
SensorsLiDAR, camera, IMU
LocalizationSLAM + satellite-image fixes
Terrain and obstacles
Path planning
Vehicle
Highlighted: my part.
My Part
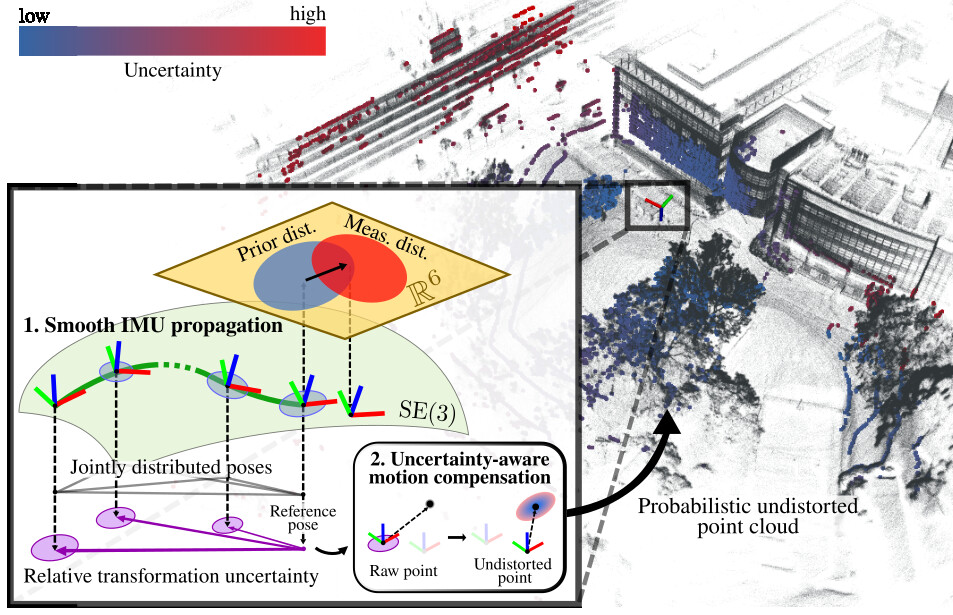
SE(3)-LIO: odometry for rough ground
IMU propagation on SE(3) and uncertainty-aware motion compensation, so jerky motion no longer breaks the odometry.
Paper: ATE 5.10 / 15.86 / 2.29 m vs. 14.07 / 17.08 / 2.50 m for FAST-LIO2
Fusion with satellite-image fixes
A per-fix confidence and a weighted solve, so fixes that jump by tens of meters carry little weight.