Winner
COMFORT Localization Challenge
Overview
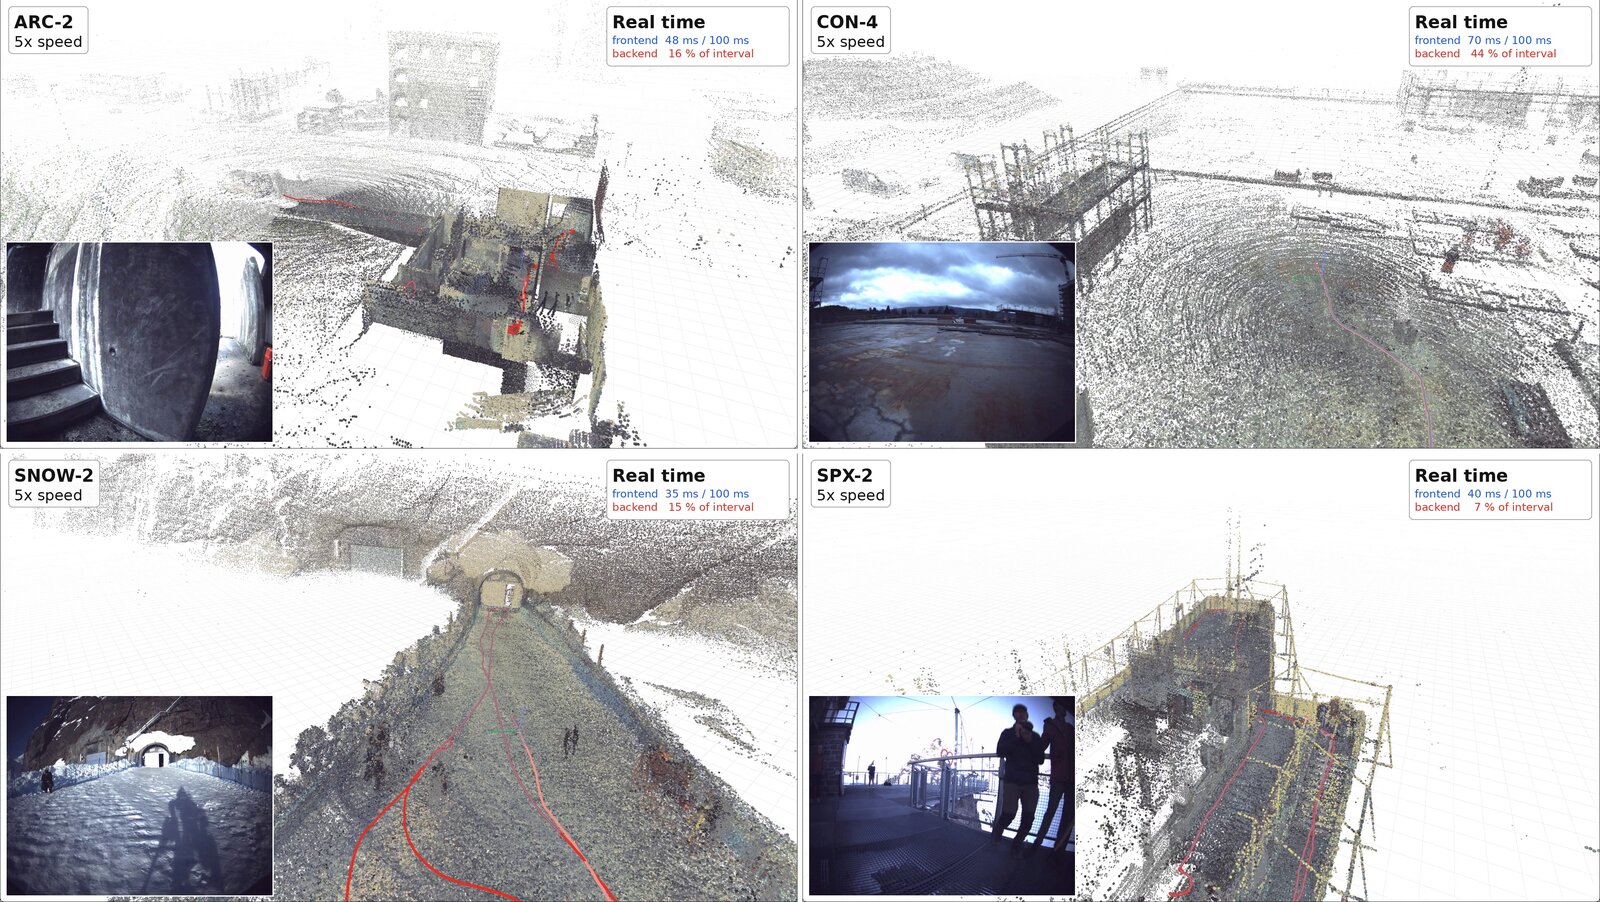
- Real-time trajectory of an ANYmal quadruped in ETH’s GrandTour field data, scored by ATE against a total station.
- Six test missions, from a collapsed building to a snowfield; no post-processing.
- Winner. Mean ATE 1.40 cm with one configuration.
Platform
ANYmal quadruped
Sensors
Two LiDARs, cameras, IMU
Environment
Collapsed and smoke-filled buildings, construction site, snowfield
Metric
Mean ATE over six missions
My Part
Lead, the whole entry
I built SE(3)-LIVOM, made every submission, and released the code and video.
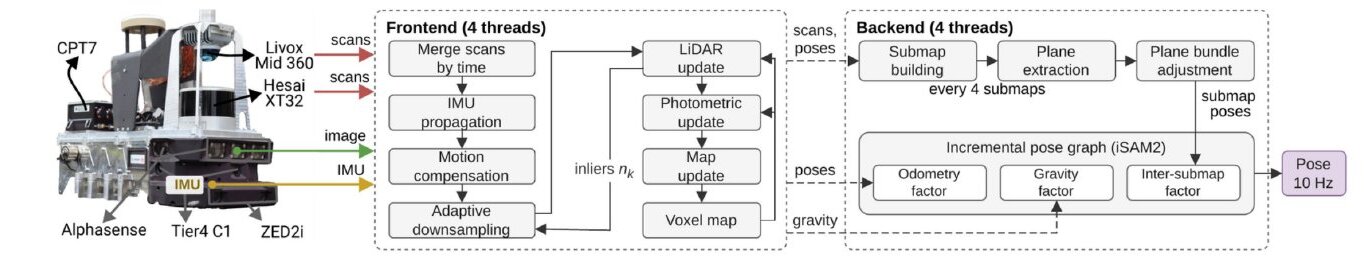
Two LiDARs and a camera in one filter
Both LiDARs merged into one time-ordered scan, plus a photometric camera update.
Corridor position loss: 19 s → ≤3 s
Adaptive downsampling
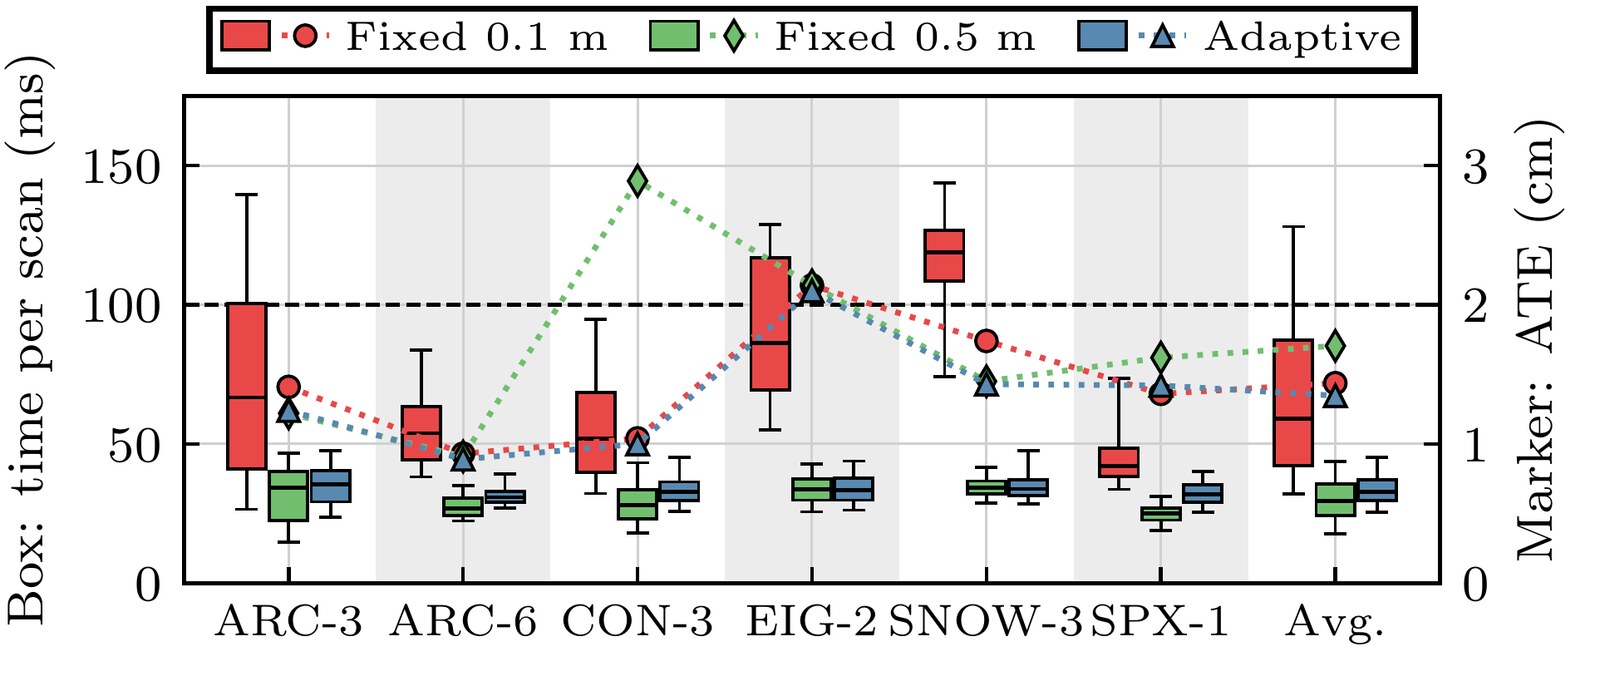
The voxel size adapts every scan to keep matched points near a target.
Best-fixed-size accuracy at ~35 ms per scan
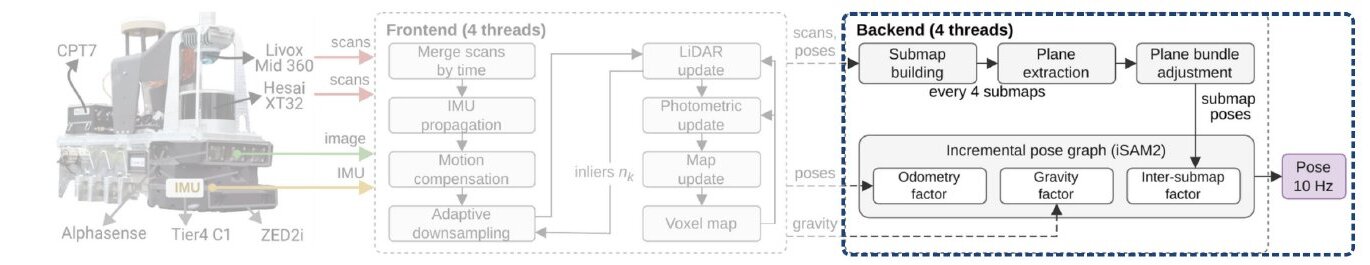
Online backend
Plane bundle adjustment on submaps, joined in an iSAM2 pose graph while the robot walks.
Test ATE 1.66 → 1.40 cm
| Method | Test mean ATE |
|---|---|
| FAST-LIVO2 (baseline we ran) | 2.16 cm |
| Ours, frontend only | 1.66 cm |
| Ours, full system | 1.40 cm |
Mean ATE RMSE over the six test missions.
Award