Challenges
Robotics challenges our team entered. Papers are listed on the home page and in the CV.
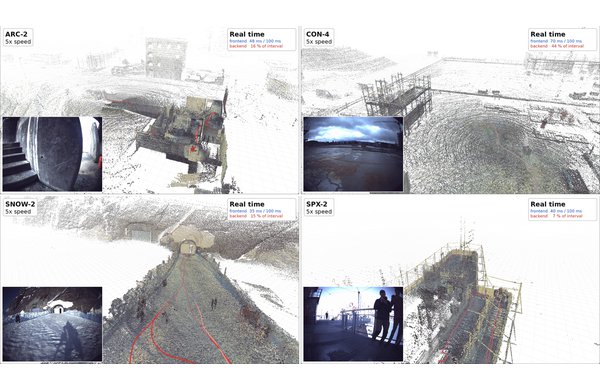
Estimate the full trajectory of an ANYmal quadruped walking through six field scenes of ETH's GrandTour dataset, scored by absolute trajectory error.
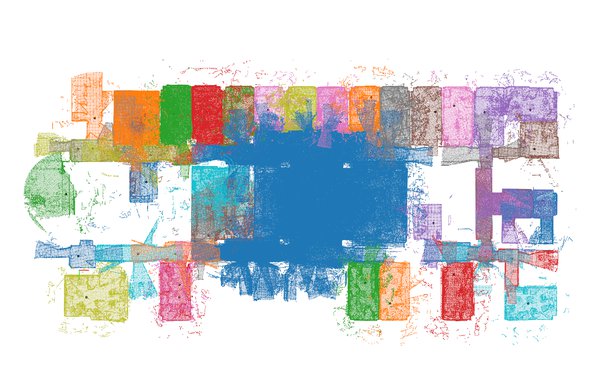
Align indoor scans of a building taken at different construction stages into one frame, with no scan-pair information and outlier scans mixed in.
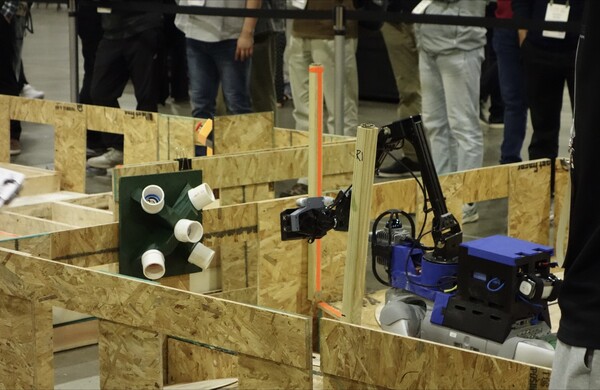
Legged robots cross rough-terrain lanes and complete inspection and manipulation tasks.
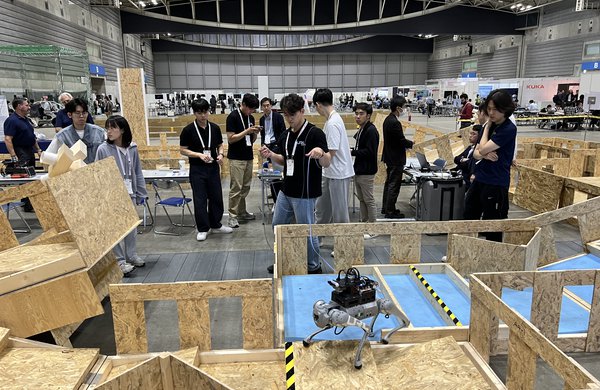
Legged robots lap a course as many times as they can in 10 minutes, using only onboard sensors and computing.
Estimate accurate trajectories from data recorded on construction sites, in narrow rooms, and in the dark. 63 teams took part.